 United States
 Bulgarian
Products
- Panasonic automation products
- Sensors
- IO-Link sensors
- Photoelectric sensors
- Miniature photoelectric sensors
- Diffuse reflective sensors with background suppression (Trigonometric sensors)
- Area sensors
- Fibre sensors
- Mark / Colour sensors
- Laser sensors
- Inductive sensors
- Safety sensors
- Measurement sensors
- Pressure & flow sensors
- Particular use sensors
- Programmable logic controllers
- Power Supplies
- Ionizers
- HMI displays
- Servo drives and motors
- LED UV curing systems
- Counters
- Timers
- Limit Switches
- Temperature Controllers
- Eco-Power Meters
- Hour Meters
- Time Switches
- Laser marking
- Laser Welding
- Sensors
- Maverick Drive Systems
- Specialized automation products
- Panasonic electronic components
- Industrial robotization
Panasonic HG-C measurement sensor
Категория: Measurement sensors
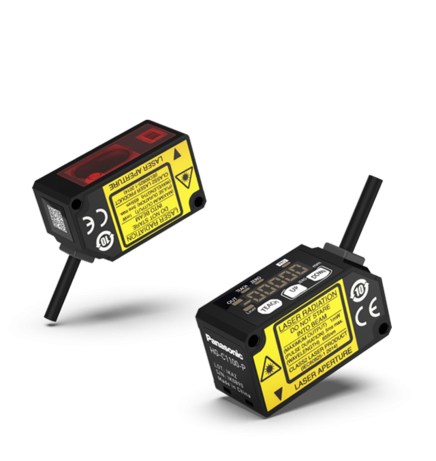
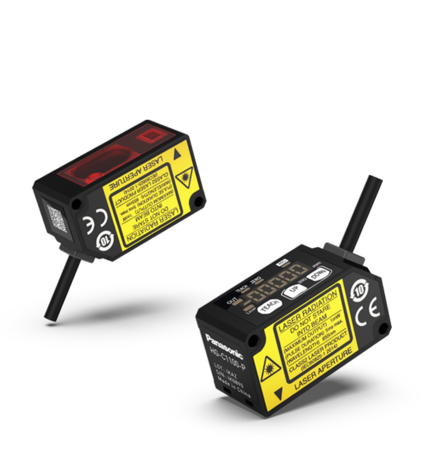
Laser measurement sensor for object detection with a repeatability of 10μm
Panasonic HG-C measurement sensor
As compact as a photoelectric sensor, the CMOS laser sensor allows to display actual measured distance as accurately as a displacement sensor.
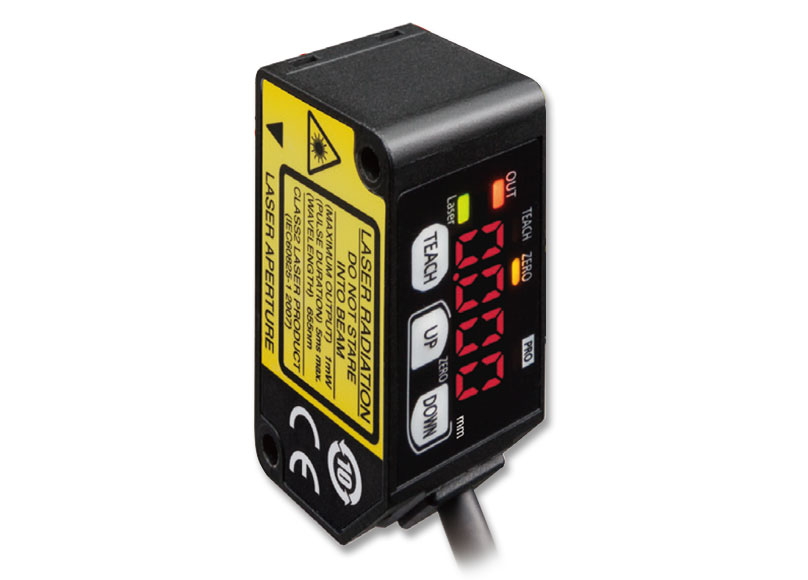
- Compact miniaturized housing - with dimensions:W20mm x H44mm x D25mm. Because the laser beam is deflected inside the sensor, it has been possible to reduce the housing to a minimum size. Parameters can be set directly at the device with the help of the buttons and the built-in display.
- Accurate > Linearity: +/-0.1% F.S.
- Precise level detection > Repeatability: 10μm
- Easy configuration:
- Perform 1-point teaching and the threshold range is set for the distance from the reference surface of the object to be detected.
- 2-point-teaching uses threshold values. For this method, all you need to do is press TEACH once for the lower (first point) and once for the upper limit (second point). This is useful for detecting objects at different distances.
- For the 3-point method, you set the threshold range by conducting the teaching at 3 points (detecting object A, B and C). After teaching, the reference points are automatically sorted in ascending order (reference point 1, 2 and 3). The thresholds are set at the midpoints between reference point 1 and 2, and 2 and 3, respectively. This is useful for detecting objects at different distances.
